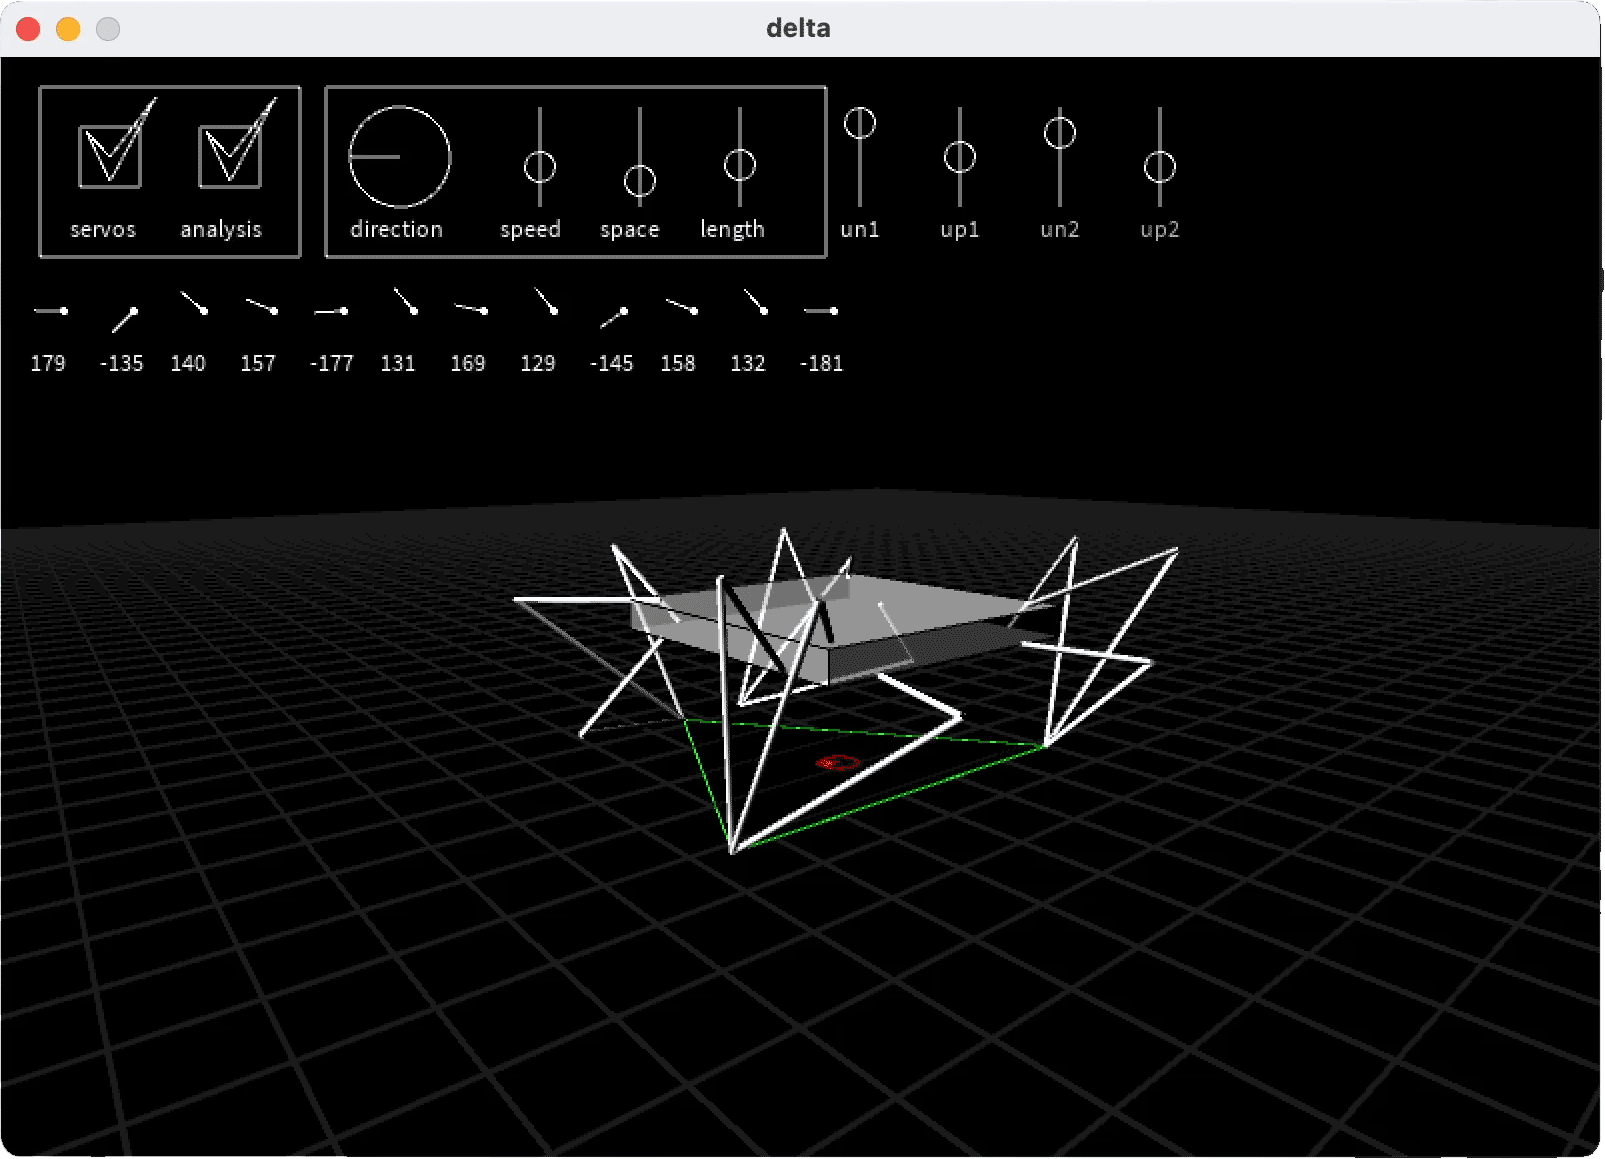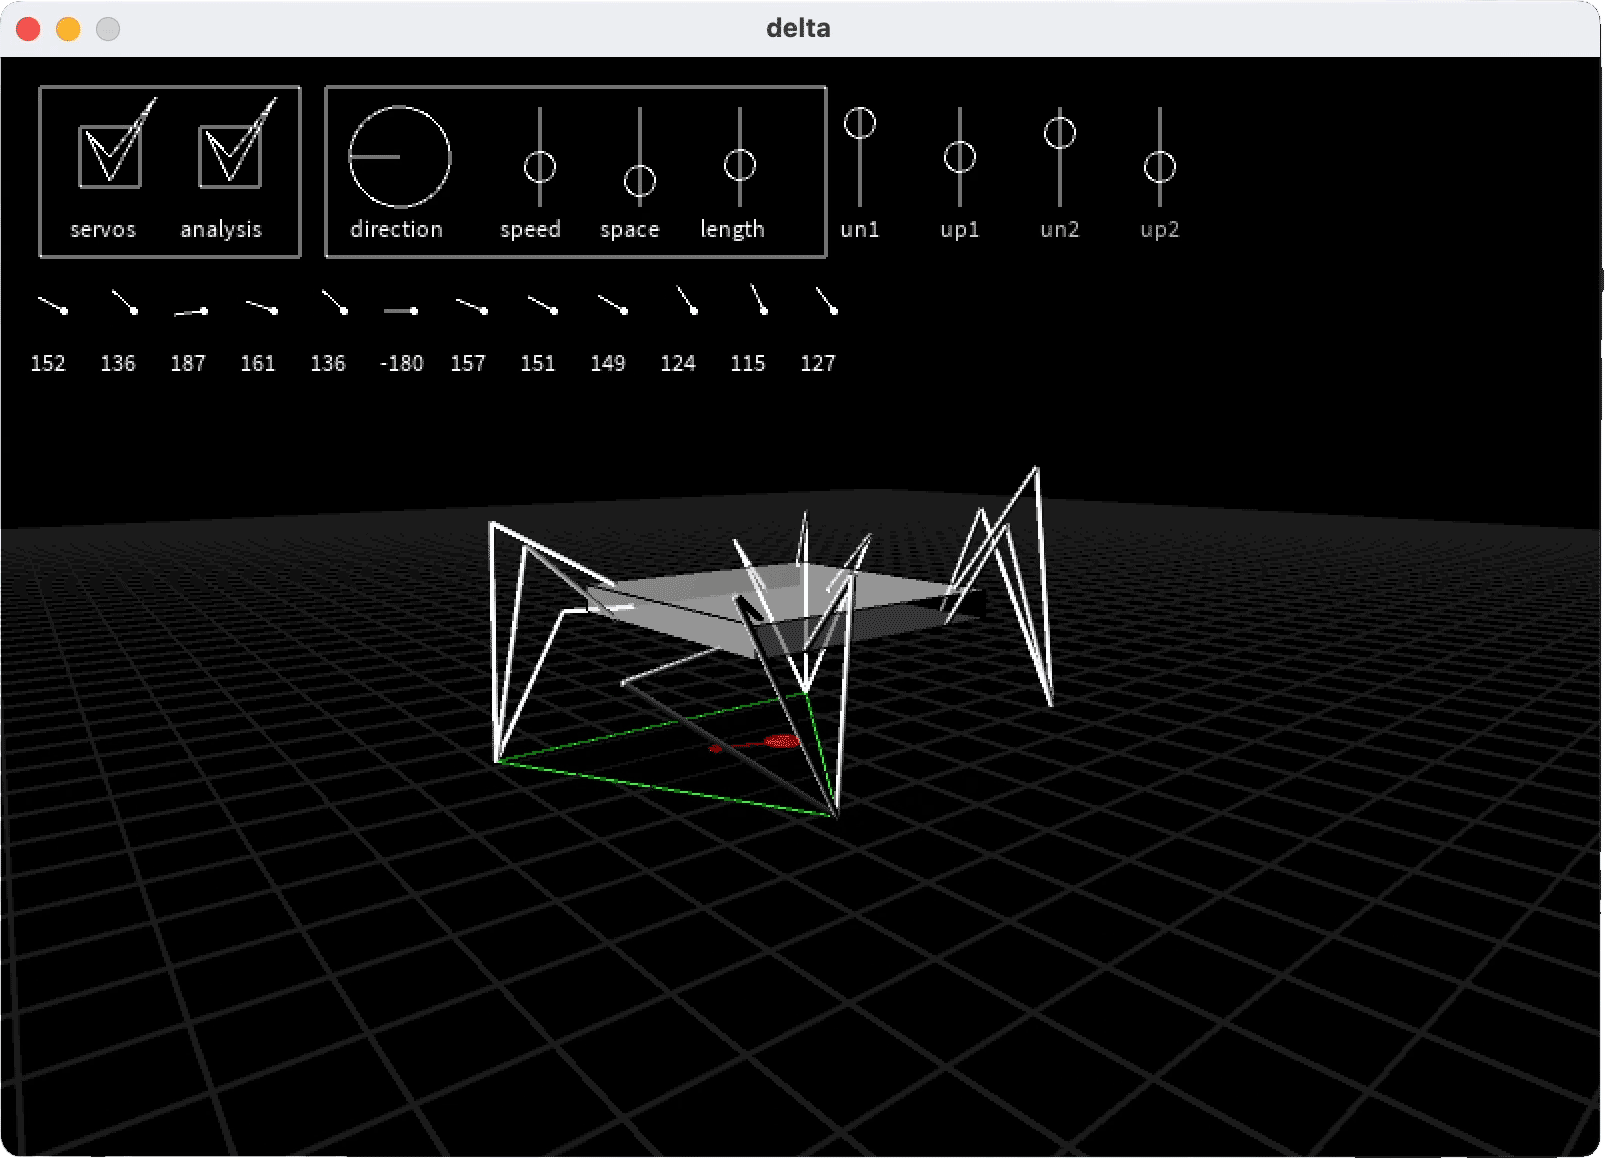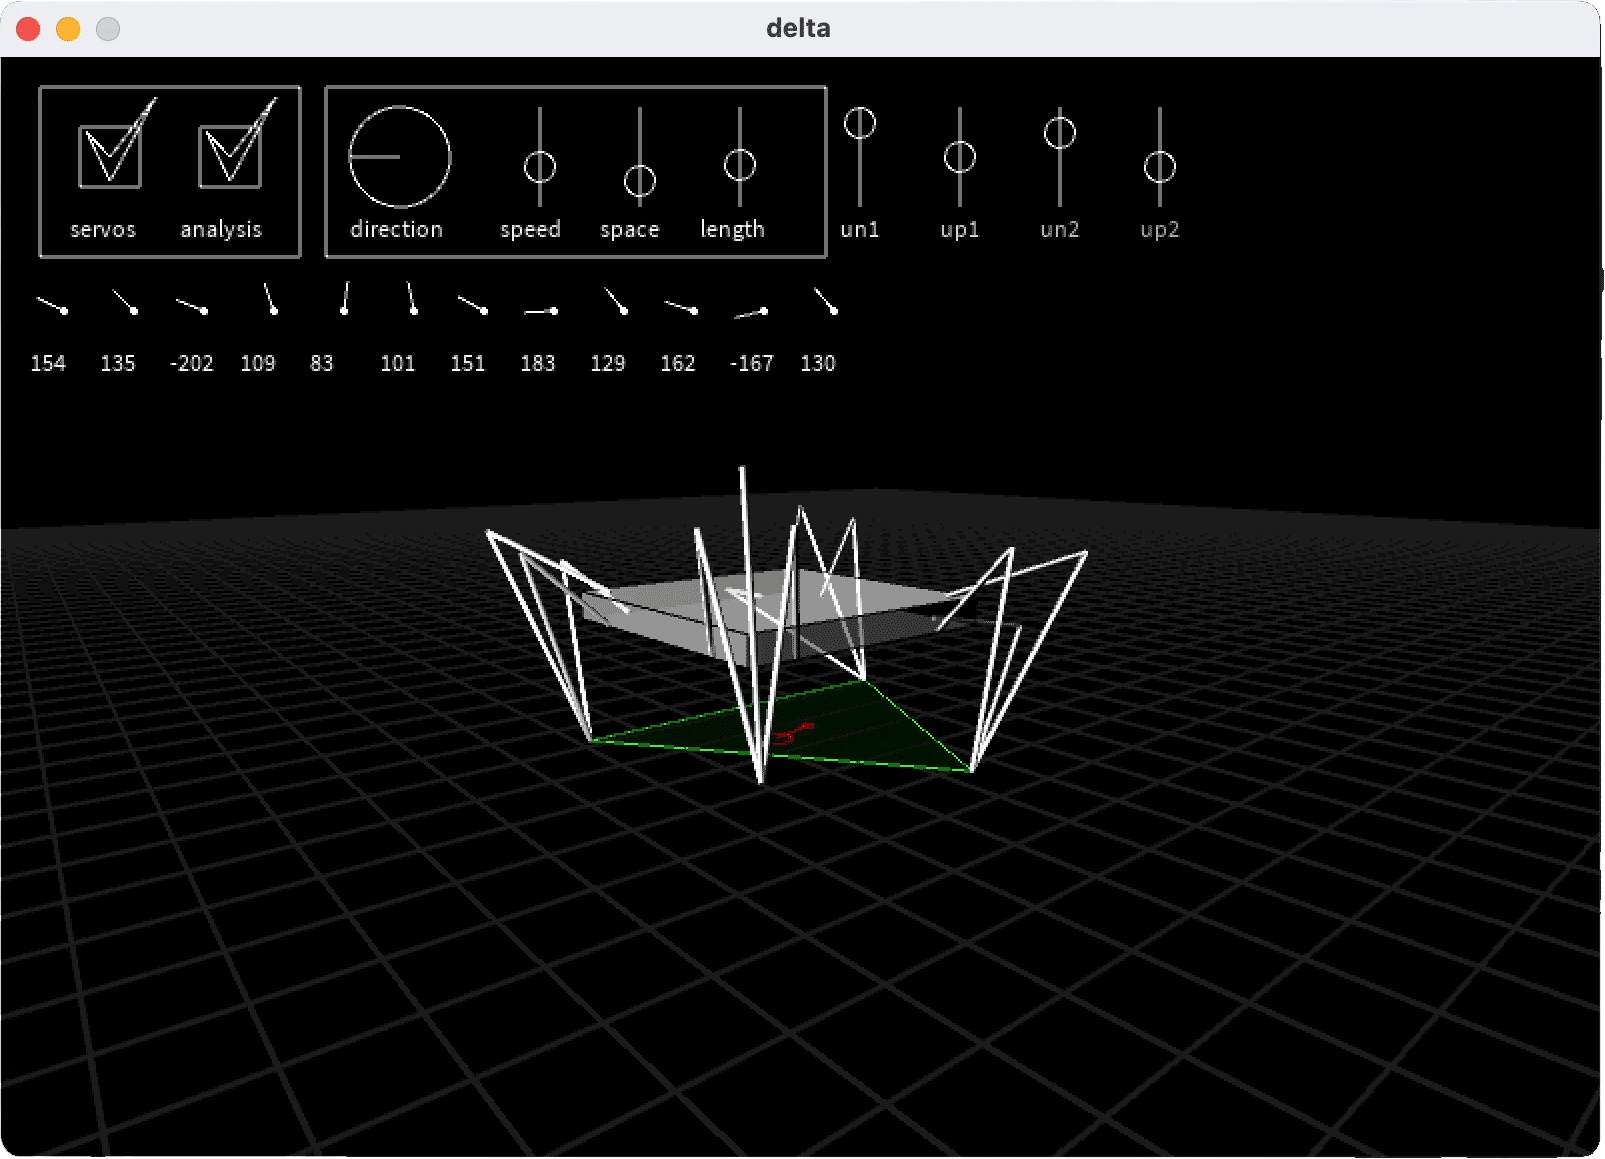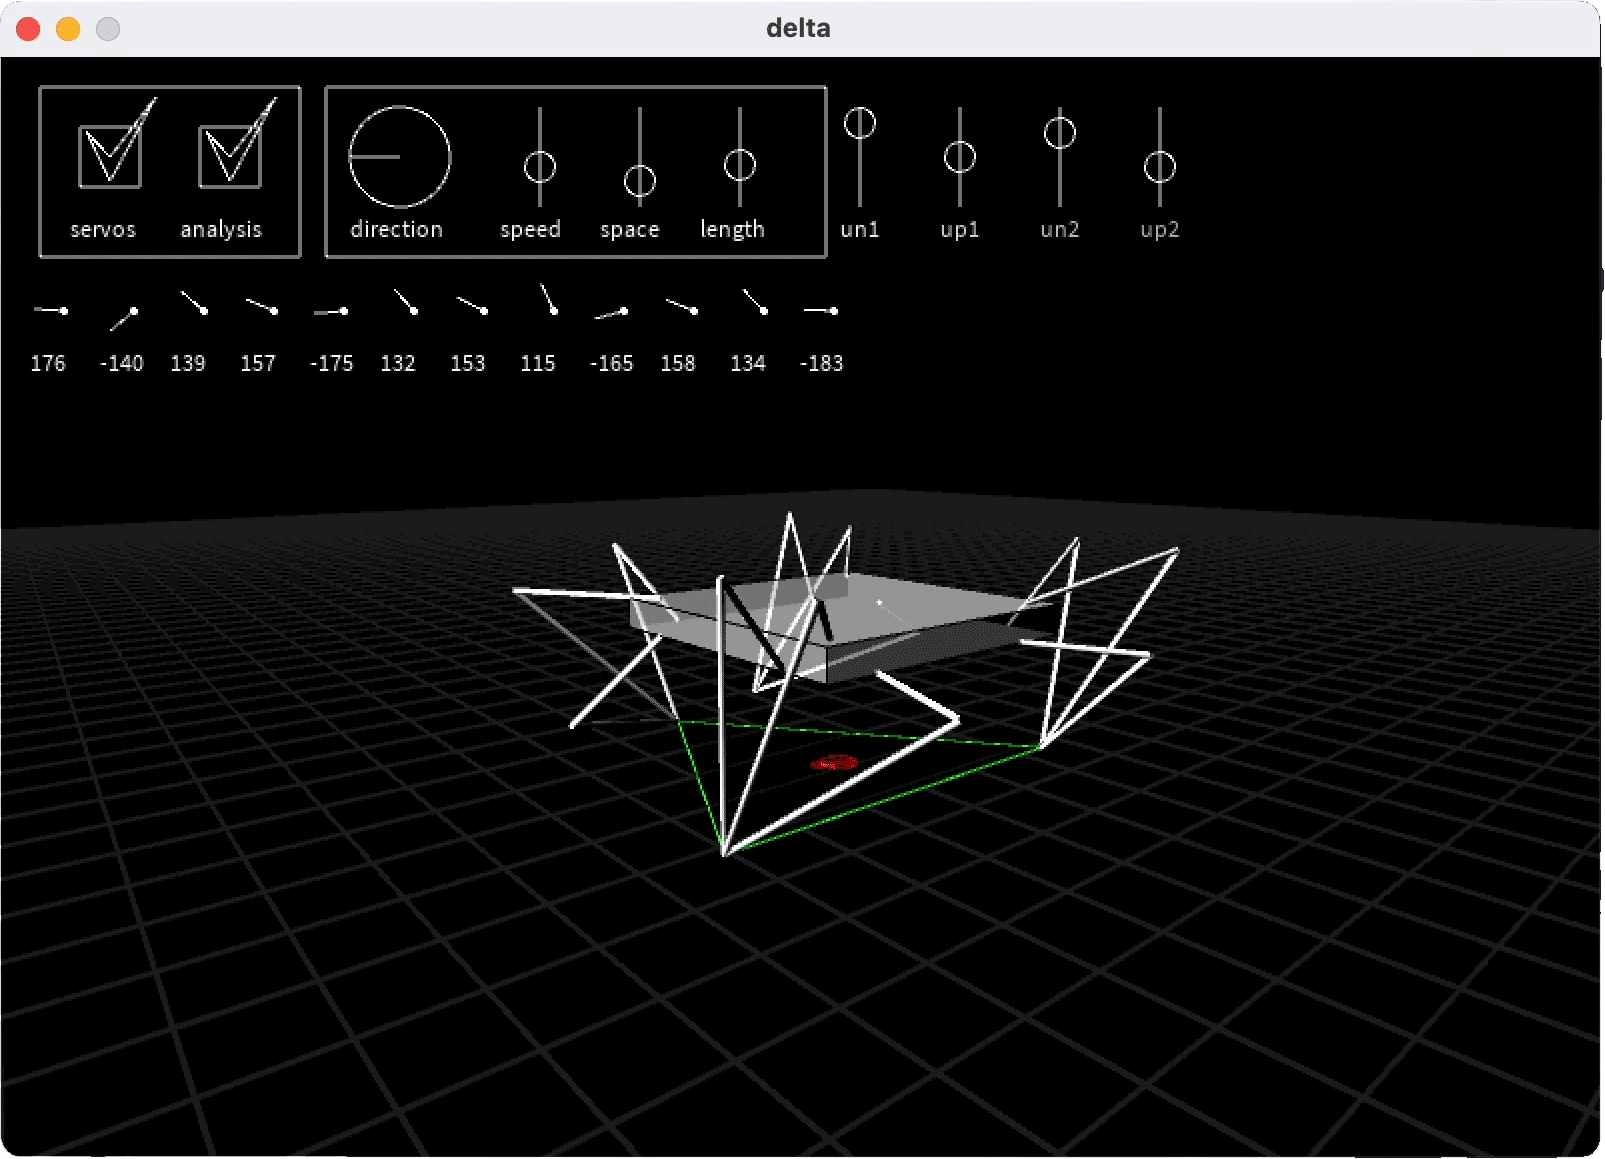
A study in Processing and OpenGL exploring a quadruped robot based on the kinematics of industrial delta robots. This leg configuration would allow the motors to be safely housed inside the main body of the robot. Due to the tight tolerances required in the knee joints, the project was never realized as a physical prototype.